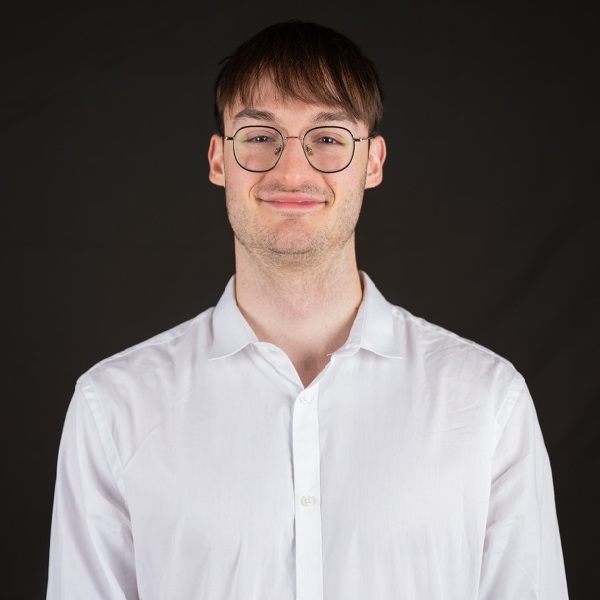
Sidney Gharib started his Master's in computer engineering at Polytechnique Montréal in August 2026, supervised by Pierre-Yves Lajoie and Giovanni Beltrame. He is interested in navigation & localization, autonomous robotics, 3D reconstruction from 2D images and representation learning.
Current Work
Sidney's research focuses on developing SLAM algorithms for robots with limited computational resources, built around the use of IMU data for localization.
Contact
Reach Sidney at sidney.gharib@polymtl.ca or on LinkedIn.